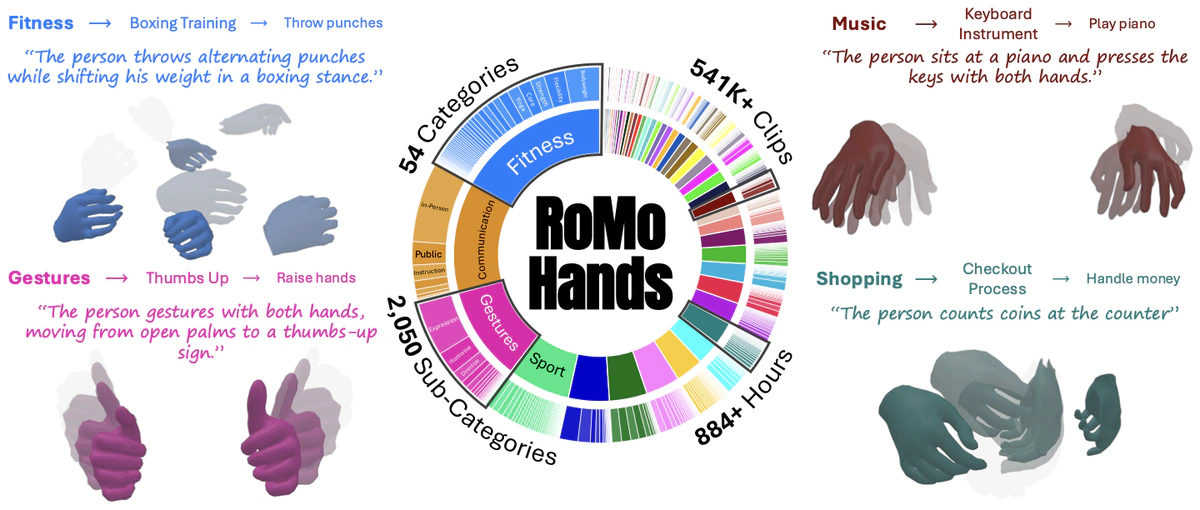
 RoMo Hands dataset overview with hierarchical action categories and bimanual motion examples.
Abstract
While text-driven body motion generation has matured, pure-hand synthesis remains bottlenecked by data. Existing datasets often treat hands as rigid end-effectors, lack fine-grained captions, or are too limited in scale to support robust generalization. We introduce RoMo Hands, an in-the-wild, text-paired dataset of ∼542K sequences (884 hours, 95.5M frames at 30fps) which is an order of magnitude larger than prior work. To ensure high-quality supervision, a stringent dexterity filter discards low-articulation sequences, focusing the distribution on complex bimanual movement. Each clip is paired with five captions at increasing granularities from global semantic tags to atomic finger states, organized under a hierarchical taxonomy. To bridge the gap between body and hand architectures, we propose a novel 393-D bimanual representation that adapts redundant body-motion paradigms to the high-DoF kinematics of hands. Systematic benchmarking of diffusion, masked-token, and autoregressive generators reveals distinct trade-offs under these hand-specific adaptations, including a sharp divergence between semantic alignment and kinematic plausibility. Our dataset, representation, and benchmark establish a rigorous foundation for the next generation of dexterous motion synthesis.
Jiahao Zhang
Ph.D. Candidate
My research interests include video understanding and generation, agentic and embodied AI as well as web development.